
HiLetgo KY-040 Rotary Encoder Module (5-Pack)
The classic KY-040 encoder — read rotation and a push-button, perfect for a manual jog control.
Best for: Manual jog control & feedback
A basic servo arm runs open-loop: you command an angle and hope it gets there. Add an encoder and the arm can actually measure where each joint is, which is the foundation of closed-loop control, teaching-by-hand, and accurate inverse kinematics. KY-040 and EC11 rotary encoders are the cheap, Arduino-friendly way to start sensing position and adding manual control knobs.
As an Amazon Associate we earn from qualifying purchases. Prices and availability are accurate as shown on Amazon at the time of purchase.
The classic KY-040 encoder — read rotation and a push-button, perfect for a manual jog control.
Best for: Manual jog control & feedback
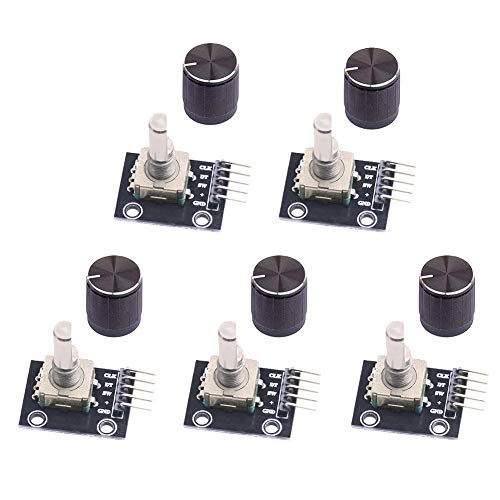
Five KY-040 encoder breakouts — pre-soldered headers, ready for the breadboard.
Best for: Breadboard prototyping

Bare EC11 encoders with knob caps — the panel-mount choice for a custom control box.
Best for: Custom control panels
Inverse kinematics for a DIY robotic arm explained simply — what forward vs inverse kinematics means, the 2-link maths, and Arduino/Python code to move your arm to an (x, y) target.
The conceptsHow do robotic arms work? Learn how joints, motors, controllers and sensors combine to move an arm precisely, explained simply for beginners and DIY builders.
Code & electronicsCopy-paste Arduino robotic arm code: Servo library setup, sweep tests, potentiometer and serial control, record/playback, smooth motion, and PCA9685.