
HiLetgo KY-040 Rotary Encoder Module (5-Pack)
The classic KY-040 encoder — read rotation and a push-button, perfect for a manual jog control.
Best for: Manual jog control & feedback

by WWZMDiB
★ Best for: Custom control panels
Bare EC11 encoders with knob caps — the panel-mount choice for a custom control box.
Opens Amazon in a new tab — current price & reviews are shown there.
As an Amazon Associate we earn from qualifying purchases. Prices and availability are accurate as shown on Amazon at the time of purchase.
The EC11 is the component-level encoder behind many KY-040 modules — useful when you want to panel-mount controls in a custom enclosure rather than use a breakout board. Six units with knob caps let you build a proper jog/teach pendant for your arm. They suit Arduino, ESP32 and Raspberry Pi, and the 5-pin layout includes the push switch for mode changes.
| Type | EC11 rotary encoder |
|---|---|
| Quantity | 6 (with knob caps) |
| Pins | 5 (incl. push switch) |
| Works with | Arduino, ESP32, Raspberry Pi |
WWZMDiB EC11 Rotary Encoder (6-Pack)
See the current price, stock and reviews on Amazon.
Inverse kinematics for a DIY robotic arm explained simply — what forward vs inverse kinematics means, the 2-link maths, and Arduino/Python code to move your arm to an (x, y) target.
Code & electronicsCopy-paste Arduino robotic arm code: Servo library setup, sweep tests, potentiometer and serial control, record/playback, smooth motion, and PCA9685.
The classic KY-040 encoder — read rotation and a push-button, perfect for a manual jog control.
Best for: Manual jog control & feedback
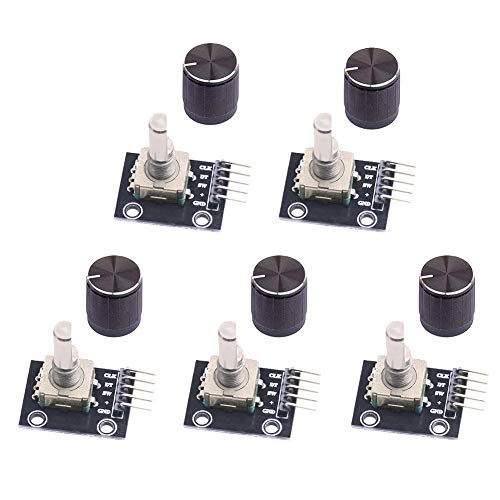
Five KY-040 encoder breakouts — pre-soldered headers, ready for the breadboard.
Best for: Breadboard prototyping

Two analog axes per stick — the easiest way to drive an arm by hand.
Best for: Hand-driving an arm with two sticks
WWZMDiB EC11 Rotary Encoder (6-Pack)
Check Price on Amazon