
STEPPERONLINE NEMA 17 Stepper Motor (2A, 59Ncm)
High-torque 48mm NEMA 17 — the standard motor for precise, repeatable arm joints.
Best for: High-torque arm joints
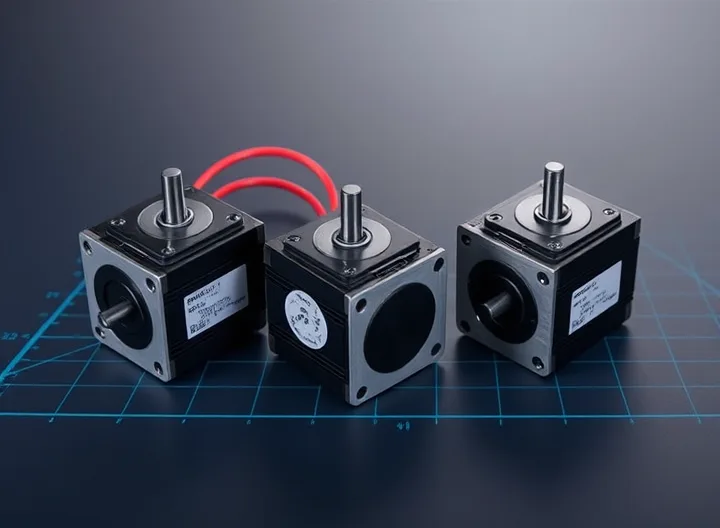
Where servos are simple and cheap, stepper motors trade convenience for precision and holding torque. A NEMA 17 moves in fixed micro-steps and stays exactly where it stopped, which is why bigger and more accurate arms — and every 3D-printed build that reuses printer parts — lean on them. They need a driver (A4988/DRV8825) and more wiring than a servo, but the payoff is repeatability you can trust.
As an Amazon Associate we earn from qualifying purchases. Prices and availability are accurate as shown on Amazon at the time of purchase.
High-torque 48mm NEMA 17 — the standard motor for precise, repeatable arm joints.
Best for: High-torque arm joints

Three compact 38mm NEMA 17 steppers — enough to drive a small 3-axis arm.
Best for: Small 3-axis stepper arms

Slim 23mm "pancake" NEMA 17 — saves weight on the wrist and outer joints.
Best for: Lightweight wrist joints
Build a stepper motor robot arm with NEMA 17 motors: torque, reduction, drivers, microstepping, AccelStepper code, homing with endstops, and when to use servos.
Start hereLearn how to build a robotic arm from scratch — the parts, degrees of freedom, wiring and code you need, plus a clear path from your first servo to a working 6-axis arm.
Builds by platformHow to build a 3D printed robotic arm — choosing a design, the best servos and bearings, print settings for strong parts, and assembling a precise 6-axis manipulator.